Stair-Climbing Robot
COMPLETESix-person ME213 team project, placing 1st in my Fall 2025 section. I contributed control software, receiver integration, electronics layout and mounting, and fabrication assistance.
PETERLAW.DEV
Mechanical Engineering + Computer Science at UH Mānoa. I work on projects connecting software, electronics, and physical systems.
SIMULATION / EMBEDDED SYSTEMS / INTEGRATION
Six-person ME213 team project, placing 1st in my Fall 2025 section. I contributed control software, receiver integration, electronics layout and mounting, and fabrication assistance.
Interactive GPU-accelerated 2D SPH fluid simulation, co-developed with Owen Poole using CPU spatial indexing and GLSL compute shaders.
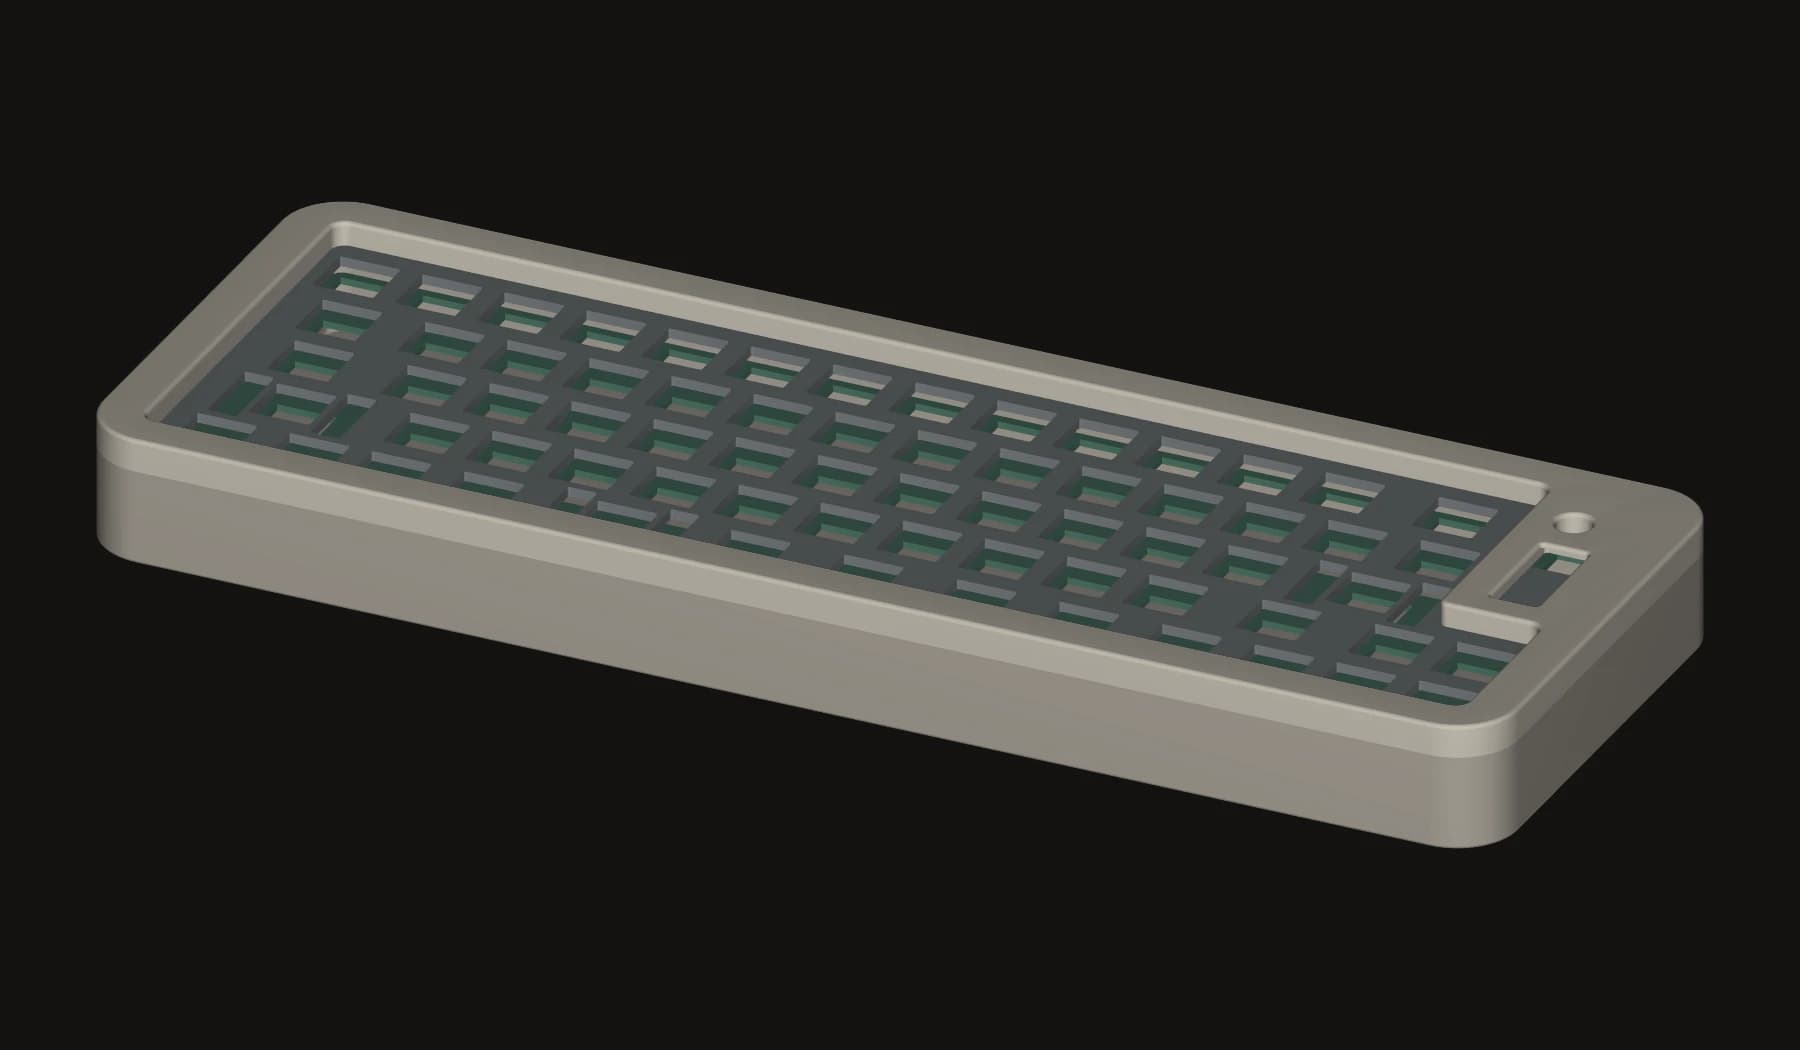
A custom 65% wireless keyboard spanning KiCad PCB design, ZMK firmware, and a self-designed enclosure through multiple physical print iterations.
A C++ planar dynamics simulator with a six-state model, rotor-thrust inputs, fixed-step RK4 integration, and OpenGL / ImGui visualization. Controls and estimation were not implemented.
I designed the complete enclosure around KiCad-derived PCB and switch-plate geometry, then iterated through multiple physical 3D prints. Development is ongoing.
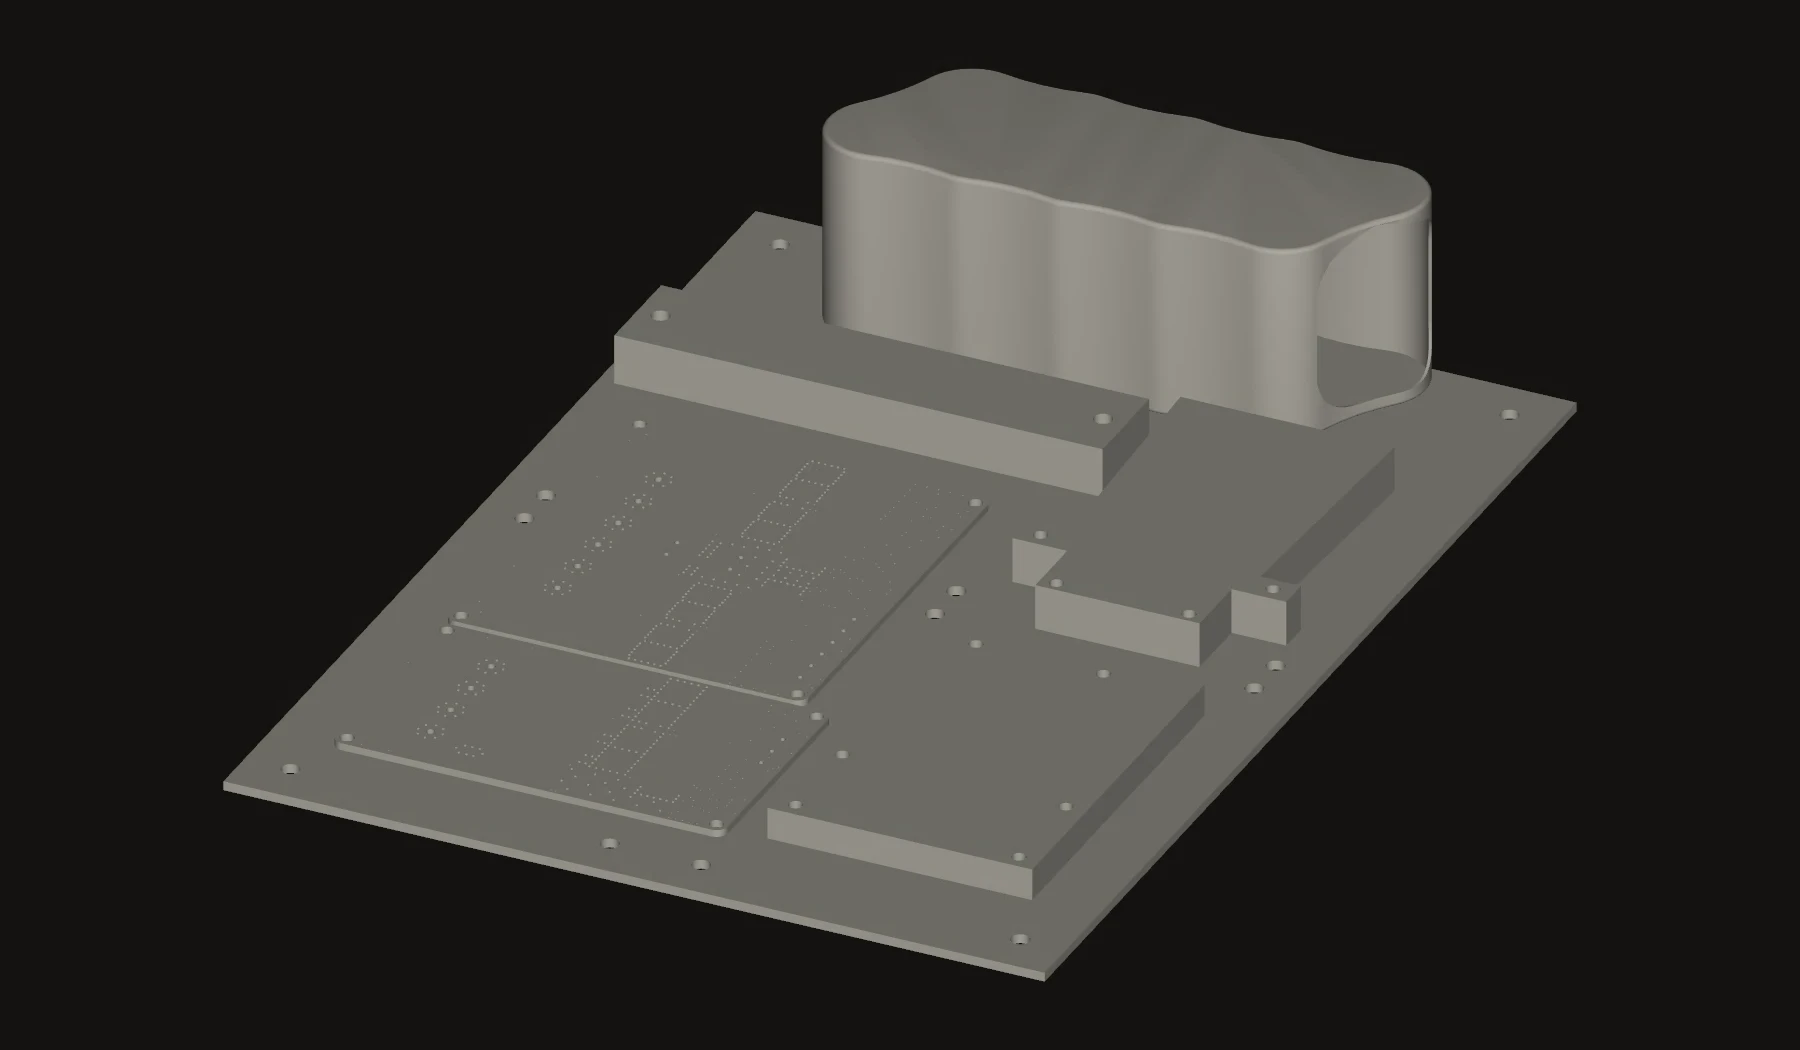
Electronics layout, mounting plate, and integration within our six-person team's stair-climbing robot. Most overall mechanical design and CAD were owned by teammates.

A working scale model of the Minecraft jukebox, with a real top-loading CD mechanism inside a fabricated plywood enclosure.
I'm a Mechanical Engineering and Computer Science student at the University of Hawaiʻi at Mānoa. I enjoy hands-on building and working through problems with other people. On teams, I often work across software, electronics, and integration.
Outside engineering, I follow motorsport and enjoy vehicles, snowboarding, hiking, video games, and time with friends. My first car was a 2010 BMW E60; its graphite-and-orange dashboard inspired this site.